
LiDAR Semantic Segmentation
On‑device LiDAR point cloud semantic segmentation with TFLite
A sample app for Ubuntu demonstrating semantic segmentation of LiDAR point clouds via TFLite Runtime. It projects a scan into a range image, classifies every point on‑device, and renders a color‑coded bird's‑eye view and range image to a minimal web interface or an image file, suitable for embedded applications.
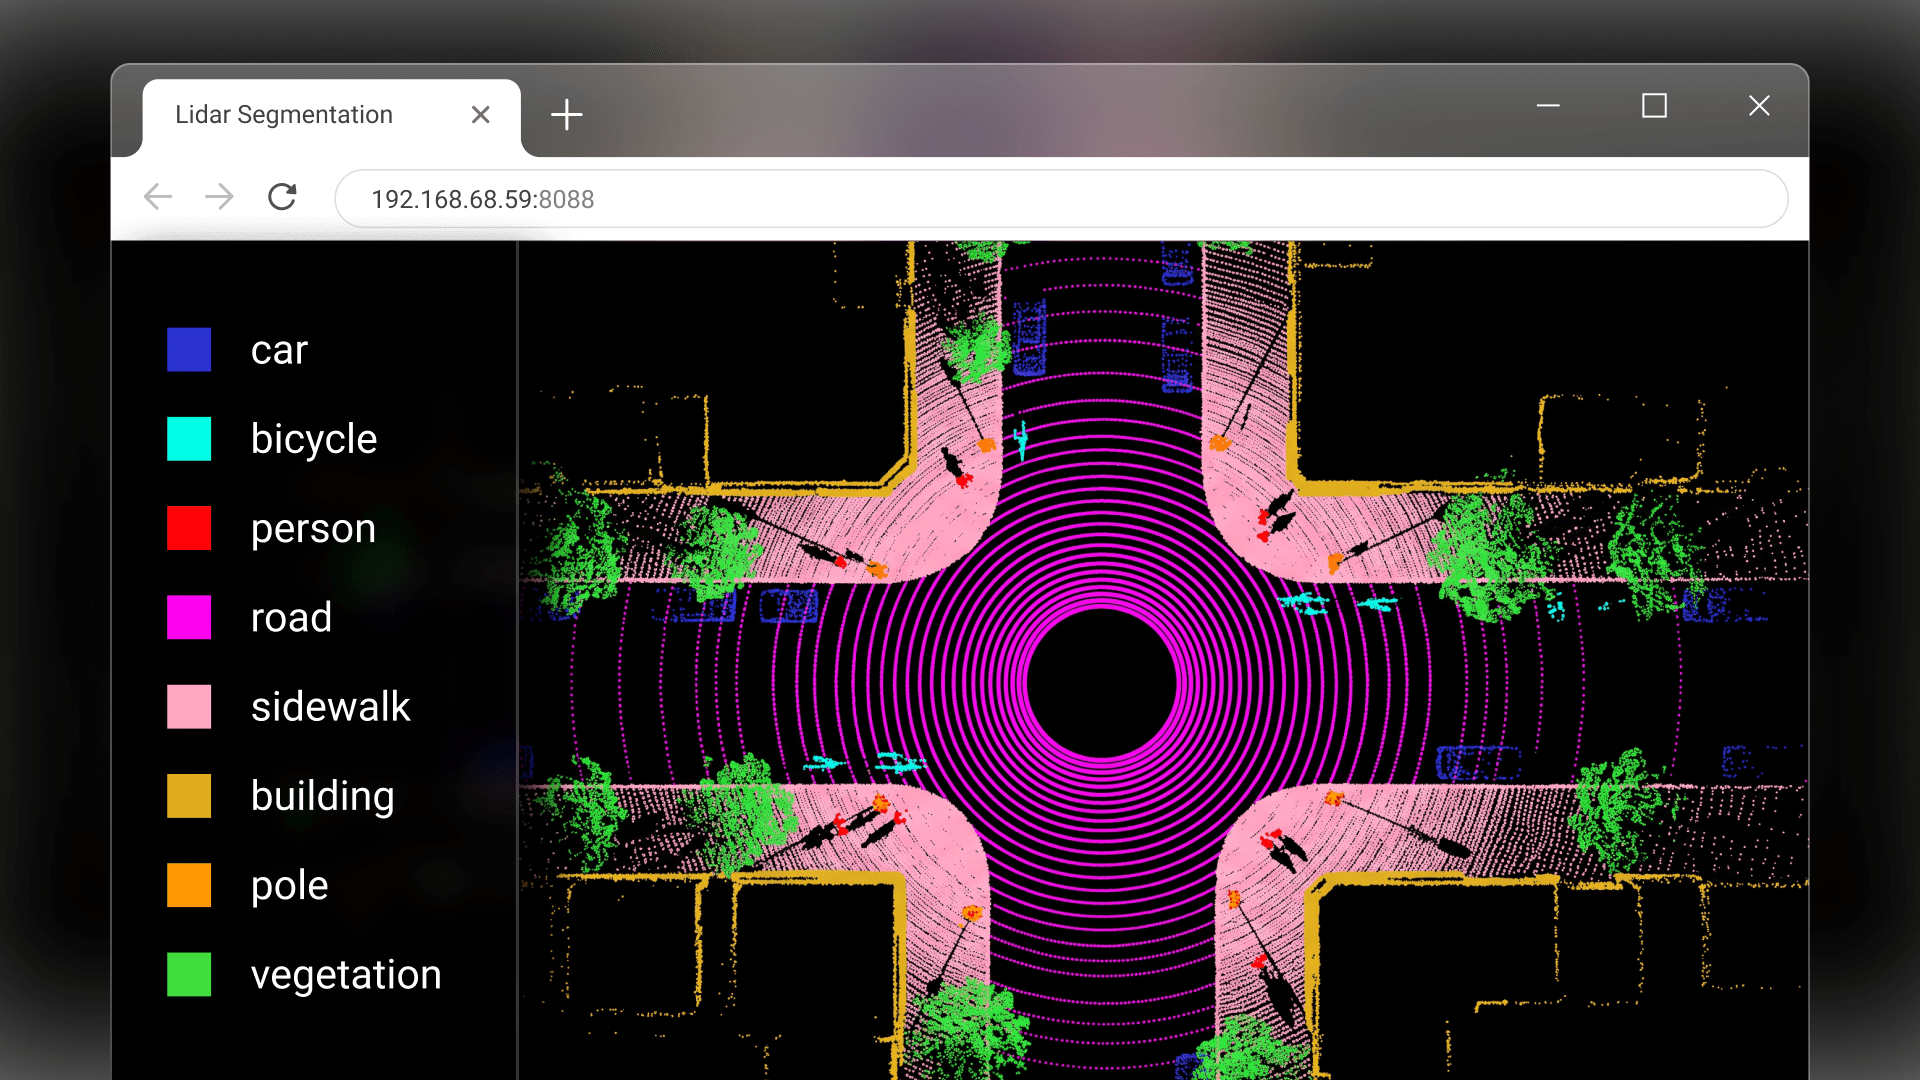
1. Choose a compatible model
2. Get source code and dependencies
3. Build and run app
Information
Operating System
Ubuntu 24.04+Language
PythonRuntime
TFLite
Use Case
Semantic Segmentation
Join Us on Slack

Join our growing community of 2000+ developers in the AI Hub Slack Channel building the future of AI
Join Now