
SuperPoint
Self‑supervised keypoint detector and descriptor for image matching and SLAM.
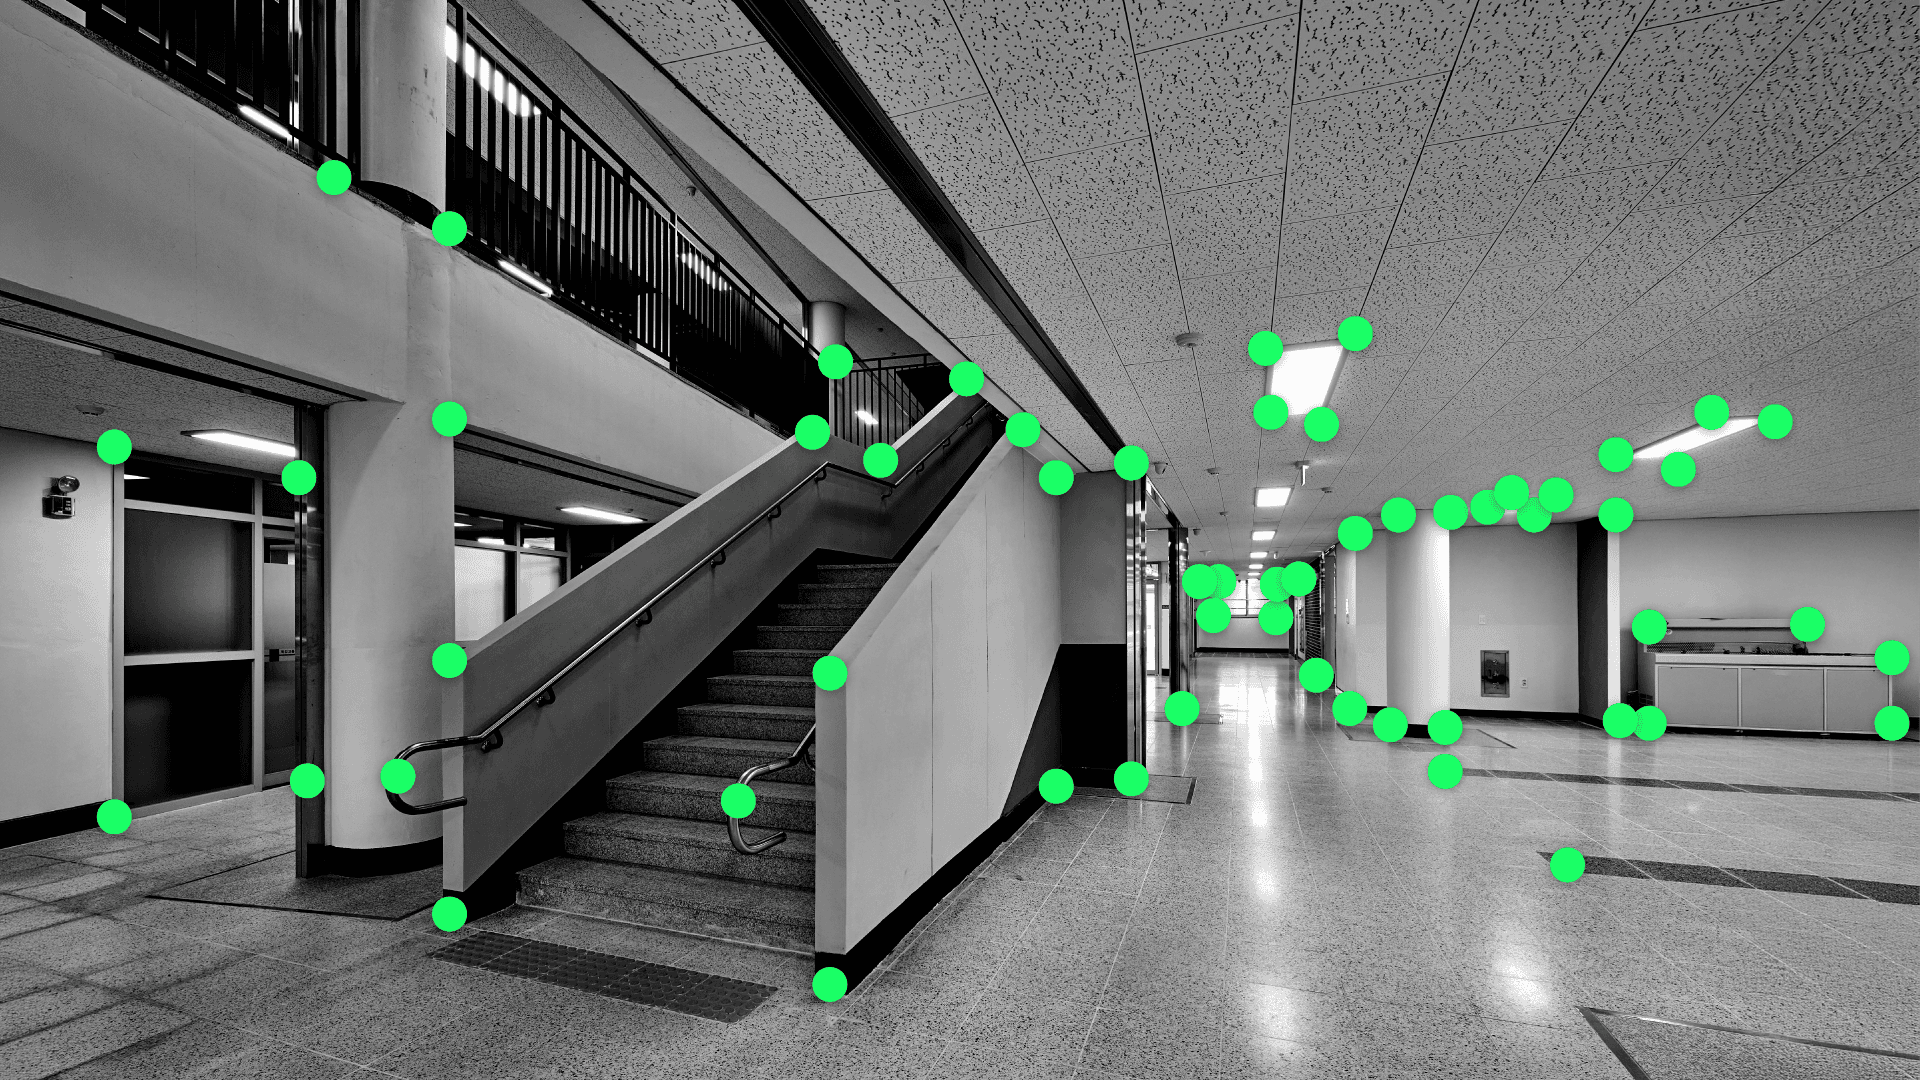
SuperPoint is a self‑supervised framework for detecting interest points and computing their descriptors in a single forward pass. It uses a VGG‑style encoder shared between a keypoint detector head and a descriptor head, trained via homographic adaptation on synthetic shapes and real images. The model outputs up to 500 keypoints per image with 256‑dimensional L2‑normalised descriptors, suitable for feature matching, visual localisation, and SLAM.
Not supported
This model is currently not supported on any Compute chipset.
To see performance metrics for this model on other chipsets, click the button below.
View for other chipsetsTechnical Details
Descriptor dimension:256
Input resolution:480x640
Model checkpoint:superpoint_v6_from_tf.pth
Model size (float):19.6 MB
Model size (w8a8):3.22 MB
Number of parameters:5.12M
Output keypoints (max):500
Applicable Scenarios
- Augmented Reality
- Visual Localisation
- Robotics
- Autonomous Vehicles
License
Model:MIT
Tags
- real-time
Supported Compute Devices
- Snapdragon X Elite CRD
- Snapdragon X Plus 8-Core CRD
- Snapdragon X2 Elite CRD
Supported Compute Chipsets
- Snapdragon® X Elite
- Snapdragon® X Plus 8-Core
- Snapdragon® X2 Elite
Looking for more? See models created by industry leaders.
Discover Model Makers